
 Cable-Driven Origami Soft Robotic Crawler
Abstract:
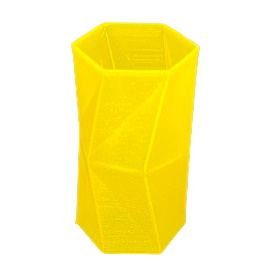
Soft robots have been gaining popularity in recent years due to their ability to adapt to complex environments and tasks. Additionally, soft robots have emerged as a promising solution for navigating through confined spaces, such as pipes. In this paper, we present a cable-driven soft robot capable of autonomous pipeline traversal using earthworm-style locomotion. The robot is comprised of a body made of Kresling geometry, as well as two end-pieces that contain soft C-springs. The body and C-springs are compressed with cables actuated by high-torque motors. This robot was designed to compete in tasks that emulate the 2023 RoboSoft competition, in which a soft robot is required to traverse pipes in various configurations. Our results from testing show the robot is able to successfully move along straight paths at any incline but struggled moving through turns. However, we believe that, with improvements, this design can be very effective for autonomous pipeline navigation and has high potential to be untethered.
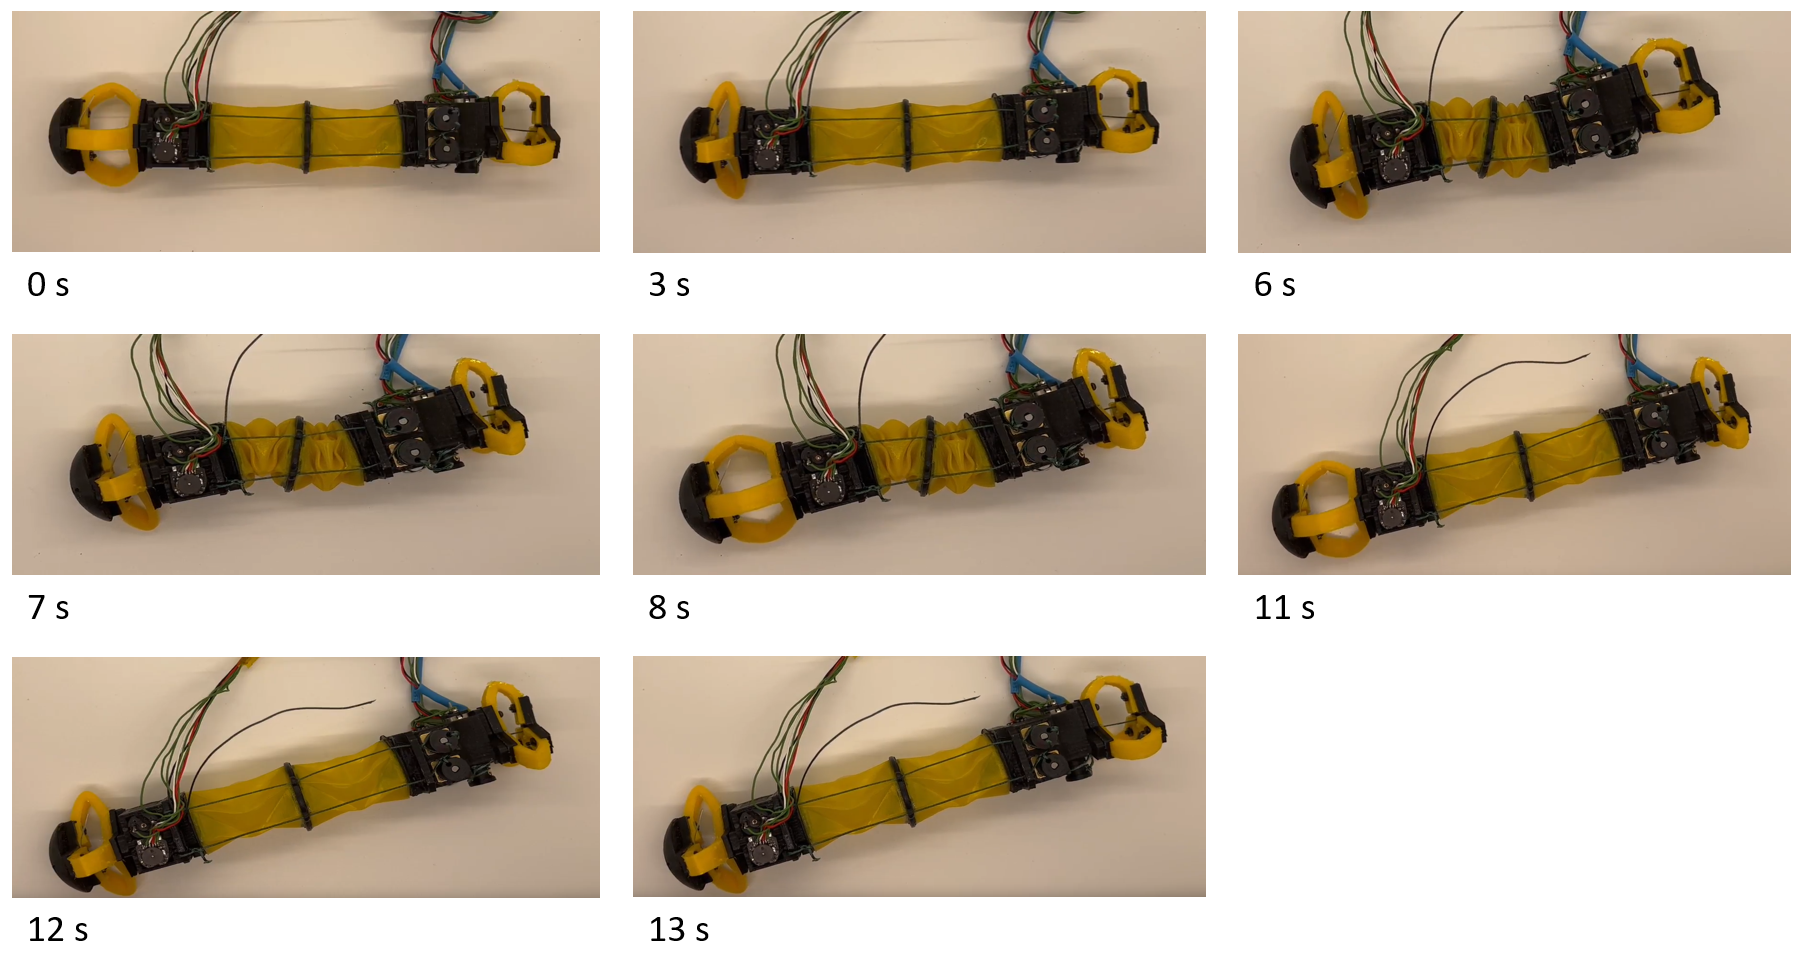
The figure below shows the locomotion cycle of the robot. See the report linked below for more details.
Featured on UM Robotics Twitter and Instagram!
Links: