
 NeRF-SLAM Docker
In this project, we built a docker environment of NeRF-SLAM: Real-Time Dense Monocular SLAM with Neural Radiance Fields by Antoni Rosinol, John J. Leonard, and Luca Carlone.
Abstract
Simultaneous localization and mapping (SLAM) is a fundamental robotics problem, which has seen a wide range of solutions. Performing visual SLAM with just monocular images and achieving 3D reconstruction is an extremely challenging problem. NeRF-SLAM achieves this through a combination of dense monocular SLAM, probabilistic volumetric fusion, and real-time hierarchical volumetric neural radiance fields. This scene reconstruction pipeline has shown to be geometrically and photometrically more accurate than other methods. We present a docker environment than allows NeRF-SLAM to work immediately for easy development and deployment. Additionally, we reproduce the results of NeRF-SLAM on the Replica dataset and perform inference on real-world custom datasets.
Our code is publicly available at Code Repo. Our datasets and video results are available at Datasets & Videos.
The figure below shows a screenshot one of our results.
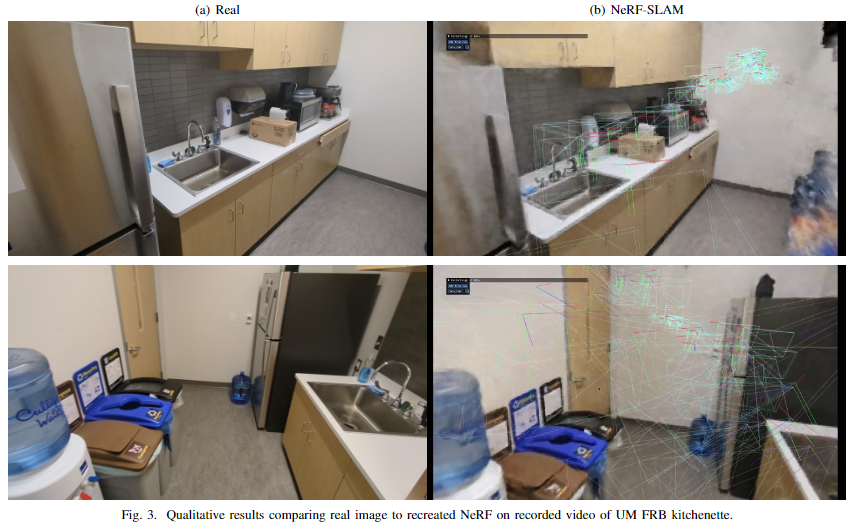
Our testing was run on a GTX 4080 with 12gb of VRAM. Our tests do not show real-time performance, and there were memory constraints, though the final renders showed high fidelity. More details can be found in the report linked below.
Links: